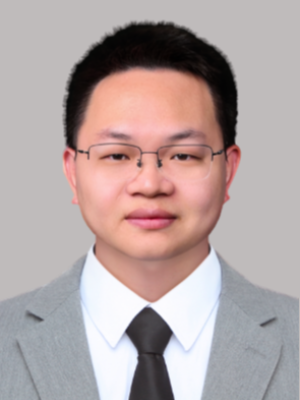
邱斌斌
副教授
E-mail:qiubb6@mail.sysu.edu.cn
研究方向:机器人/机械臂控制、神经网络/神经动力学、智能控制、智能计算与优化、多智能体系统
个人主页:https://www.researchgate.net/profile/Binbin-Qiu/research
教师简介
邱斌斌,博士,副教授,博士生导师。2018年6月毕业于中山大学信息与通信工程专业获博士学位。2018年9月至2023年5月分别在中山大学计算机学院和智能工程学院担任博士后和副研究员,2023年6月起担任中山大学智能工程学院副教授。
目前已发表/录用SCI期刊论文40余篇,出版英文专著1部,授权发明专利6件,其中已转化3件。主持国家级和省部级等项目7项,其中含国家自然科学基金项目2项,广东省自然科学基金项目2项。
学科方向
学科专业:智能科学与技术(本科);控制科学与工程、电子信息(硕博)
研究方向:机器人/机械臂控制、神经网络/神经动力学、智能控制、智能计算与优化、多智能体系统等
讲授课程:信号与系统、通信原理(本科);高等工程数学(二)、认知机器人(硕博)
科研项目
[1] 国家自然科学基金面上项目,基于自适应离散混合神经动力学优化的异构机器人统一智能控制研究,主持
[2] 国家自然科学基金青年项目,面向复杂未来时变问题的新型递归神经动力学模型设计与研究,主持
[3] 中国博士后科学基金面上项目,冗余度机械臂等效性及混合层优化方案的设计与研究,主持
[4] 广东省自然科学基金面上项目,针对未来时变问题的新型离散鲁棒神经网络算法设计与研究,主持
[5] 广东省自然科学基金面上项目,针对不同层未来时变问题的离散递归神经网络模型设计、实现与应用,主持
[6] 中央高校青年教师培育项目,机械臂背景的离散递归神经网络扰动抑制模型设计与研究,主持
[7] 深圳市出站博士后资助项目,冗余度机器人运动控制,主持
[8] 惠州市科技计划项目,面向石化园区安全的智能巡检机器人关键技术研发与应用,中大方主持
[9] 国家自然科学基金面上项目,基于高精度时间离散公式与神经动力学的未来时变问题求解,参与
[10] 广东省自然科学基金面上项目,运动学模型未知条件下的软体机械臂智能控制关键技术研究,参与
[11] 广州市重点领域研发计划项目,基于类脑计算的视觉感知与控制关键技术研究及机器人集成,参与
论著专利
[1] Binbin Qiu, Zijian Huang, Chao Zhong, Jinjin Guo, and Yu Han, “An adaptive inverse-free robust DZNN for solving future linear equation and inequality systems with manipulator application,” IEEE Transactions on Industrial Electronics, in press, 2026
[2] Guangfeng Cheng, Yu Han, and Binbin Qiu*, “A predefined-time fuzzy adaptive RNN for time-dependent bound-constrained nonlinear optimization with applications,” IEEE Transactions on Fuzzy Systems, vol. 33, no. 12, pp. 4358-4370, 2025
[3] Yu Han, Chao Zhong, and Binbin Qiu*, “A novel DZNN controller for end-actuator tracking and multiobstacle avoidance of joint-constrained redundant manipulators,” IEEE Transactions on Industrial Electronics, vol. 72, no. 11, pp. 11541-11550, 2025
[4] Yu Han, Guangfeng Cheng, and Binbin Qiu*, “A triple-integral noise-resistant RNN for time-dependent constrained nonlinear optimization applied to manipulator control,” IEEE Transactions on Industrial Electronics, vol. 72, no. 6, pp. 160-173, 2025
[5] Binbin Qiu, Jinjin Guo, Mingzhi Mao, and Ning Tan, “A fuzzy-enhanced robust DZNN model for future multiconstrained nonlinear optimization with robotic manipulator control,” IEEE Transactions on Fuzzy Systems, vol. 32, no. 1, pp. 160-173, 2024
[6] Binbin Qiu, Jinjin Guo, Song Yang, Peng Yu, and Ning Tan, “A novel discretized ZNN model for velocity-layer weighted multicriteria optimization of robotic manipulators with multiple constraints,” IEEE Transactions on Industrial Informatics, vol. 19, no. 5, pp. 6717-6728, 2023
[7] Binbin Qiu, Jinjin Guo, Xiaodong Li, Zhijun Zhang, and Yunong Zhang, “Discrete-time advanced zeroing neurodynamic algorithm applied to future equality-constrained nonlinear optimization with various noises,” IEEE Transactions on Cybernetics, vol. 52, no. 5, pp. 3539-3552, 2022
[8] Binbin Qiu, Xiao-Dong Li, Jinjin Guo, and Ning Tan, “New jerk-level configuration adjustment schemes applied to constrained redundant robots,” IEEE Transactions on Industrial Informatics, vol. 18, no. 4, pp. 2528-2538, 2022
[9] Binbin Qiu, Jinjin Guo, Xiaodong Li, and Yunong Zhang, “New discretized zeroing neural network models for solving future system of bounded inequalities and nonlinear equations aided with general explicit linear four-step rule,” IEEE Transactions on Industrial Informatics, vol. 17, no. 8, pp. 5164-5174, 2021
[10] Binbin Qiu, Yusheng Zeng, Jinjin Guo, Yu Han, Guangfeng Cheng, “A novel fuzzy-power robust RNN model for tracking control of mobile robot manipulators,” Neurocomputing, vol. 682, p. 133459, 2026
[11] Binbin Qiu and Xiao-Dong Li, “Jerk-layer repetitive motion and direction control scheme of redundant robot resolved via new discretized zeroing neural network model,” Neurocomputing, vol. 511, pp. 237-246, 2022
[12] Jinjin Guo, Zhanhao Xiao, Jianhua Guo, Xianglei Hu, and Binbin Qiu*, “Different-layer control of robotic manipulators based on a novel direct-discretization RNN algorithm,” Neurocomputing, vol. 620, p. 129252, 2025
[13] Guangfeng Cheng, Binbin Qiu, Jinjin Guo, and Yu Han, “A robust direct-discretized RNN for time-dependent optimization constrained by nonlinear equalities and its applications,” IEEE/CAA Journal of Automatica Sinica, vol. 12, no. 9, pp. 1-12, 2025
[14] Yunong Zhang, Binbin Qiu, and Xiaodong Li, Zhang-Gradient Control, Singapore: Springer-Verlag, 2020
[15] 邱斌斌、李晓东、郭津津,一种机械臂运动控制方法、装置、设备及介质,发明专利
[16] 邱斌斌、李晓东、郭津津,基于离散时间神经动力学的移动机器人重复运动控制方法及系统,发明专利
[17] 邱斌斌、彭基培、钟超、韩瑜,一种关节约束冗余度机械臂末端跟踪和多障碍物躲避方法,发明专利
[18] 邱斌斌、刘思雅、程广峰、韩瑜,一种模糊增强三积分抗噪递归神经网络求解器设计方法,发明专利
荣誉获奖情况
[1] 2021年被认定为深圳市高层次人才
[2] 2024年获IRAC国际学术会议优秀报告奖
社会服务及兼职
[1] IEEE Senior Member、中国自动化学会(CAA)会员、中国仿真学会会员
[2] IEEE/CAA JAS、IEEE TC、IEEE TNNLS、IEEE TSMCS、IEEE TIE、IEEE TII等国际学术期刊审稿人
[3] 教育部学位与研究生教育发展中心论文评审专家、国家自然科学基金评审专家
联系方式
电子邮箱:qiubb6@mail.sysu.edu.cn, qiubb2013@163.com
欢迎勤思好学、热爱科研的博士生、硕士生、本科生与我邮件联系和加入团队!