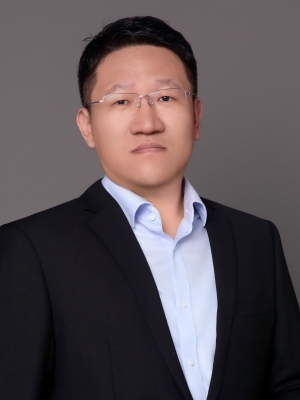
王涛
教授
E-mail:wangt339@mail.sysu.edu.cn
研究方向:智能自主无人系统、先进制导与控制、认知智能机器人、高端装备智能运维与健康管理、、多飞行器任务协同规划与智能决策等
教师简介
王涛,博士,教授,博士生导师,中山大学“百人计划”引进人才,深圳市孔雀计划特聘岗B类,南方海洋科学与工程广东省实验室智能海洋无人装备创新团队核心成员。主要从智能无人系统相关态势感知认知、先进制导规划与决策控制技术研究,面向无人系统的具身智能多学科交叉应用基础研究。曾任职中国运载火箭技术研究院(简称航天一院),长期从事飞行器GNC系统总体设计研究工作
发表高水平SCI/EI期刊和国内外会议论文总计67篇,获授权发明专利34项,制定行业协会团体标准1项,第一完成人获中国商业联合会科学技术奖技术发明奖特等奖、中国自动化学会技术发明二等奖、中国发明协会发明创业人物奖等省部级科技奖励5项,2次获航天一院长征贡献奖,在首届/第二届全国大模型与决策智能大会、第六届载人航天学术大会、国际低空产业大会、国际自主无人系统大会ICAUS2023/2024/2025、认知计算与决策智能大会CCHI2025等多个国际国内大会组织或主持专题论坛并做专题报告,担任中国自动化学会、中国指挥与控制学会、中国宇航学会、中国图形图像学会等多个学会专业委员会委员
电子邮箱:wangt339@mail.sysu.edu.cn
办公地址:深圳市光明区中山大学深圳校区工学园2栋-804/806
教育背景
2000.09-2004.07 西北工业大学 航天学院 探测制导与控制 工学学士
2004.09-2007.04 北京航空航天大学 仪器光电学院 精密仪器及机械 工学硕士
2007.05-2011.12 西安交通大学 人工智能与机器人研究所 控制科学与工程 工学博士
研究方向
智能自主无人系统、先进制导与控制、认知智能机器人、高端装备智能运维与健康管理、多飞行器任务协同规划与智能决策等
欢迎有志于从事智能无人系统应用基础研究的同学加入,每年招收博士生1-2名,硕士生2-3名,招生专业包括控制科学与工程、计算机科学与技术、电子信息工程、应用数学、机械及其自动化、人工智能、精密仪器及机械、航空宇航科学与技术、生医工等。科研任务饱满、经费充足,提供优越的科研条件,自由多样化科研工作模式。
常年招收博士后、专职科研人员,欢迎联系咨询加入。请关注实验室公众号CCCLab
开放、自由、务实、向上、不内卷的实验室科研环境氛围助力每一位优秀的你快速稳定成长
科研及教学
先后主持承担领域基金重点项目、前沿创新、十三五装备预研、国家自然基金、重大专项工程以及预研型号等项目20多项,近五年主责科研经费三千多万,主要科研业务覆盖无人系统、精确制导与控制等技术领域,应用覆盖陆、海、空、天无人装备智能化关键核心技术。
讲授课程:飞行器概论、无人系统导论、 认知科学基础、 传感器技术及信息融合、 工业人工智能
代表性论文
期刊论文:
Chen Yuedong, Wang Tao*, Ma Bo, Tong Yong, Xue Yuyang, Liu Xueru. Multi-Layer Robustness Enhancement for Low-Altitude UAVs via EKF Fusion and SAC Optimization[J]. Aerospace Science and Technology. Accepted on Sept. 2, 2026. (中科院一区TOP JCR Q1 IF= 6.4)
Hongrun Wang; Tao Wang*; Jingshuai Cao; Xueru Liu. IC-VTP: An Intent-Conditioned Reinforcement Learning Method for Robust Long-Term Trajectory Prediction of Non-Cooperative Vessels[J]. Ocean Engineering. Vol. 366, Part 4,
2026,127570. https://doi.org/10.1016/j.oceaneng.2026.127570.(中科院二区TOP期刊,JCR Q1 SCI IF=6.3)Fei Wang,Jiayue Sun,Jiaxin Hu,Xiaoyu Luo,Tao Wang*. A dual-layer evaluation framework for USV maritime patrol based on time-varying Markov chains: Unpredictability index design and adversarial verification[J]. Ocean Engineering. Vol. 362, Part 3, 2026, 126408, ISSN 0029-8018, https://doi.org/10.1016/j.oceaneng.2026.126408.(中科院二区TOP期刊,JCR Q1 SCI IF=6.3)
- Jiaxin Hu, Tao Wang*, Fei Wang, Hongrun Wang, Jingshuai Cao. Causal-Guided Disentanglement for debiasing Recommendation via counterfactual reasoning[J]. Knowledge-Based Systems. Vol. 348, 2026, 116380,(中科院一区TOP期刊,JCR Q1, SCI IF=8.0) https://doi.org/10.1016/j.knosys.2026.116380.
- Yuyang Xue, Tao Wang*, Bo Ma, Yiwen Hu, Chen Gao, Feng Xie. Human-inspired predictive trajectory planning for fixed-wing unmanned aerial vehicles in contested environments[J]. Engineering Applications of Artificial Intelligence[J]. Vol. 177, Part 2,2026,115000,ISSN 0952-1976, https://doi.org/10.1016/j.engappai.2026.115000.(中科院一区 TOP JCR Q1 IF=9.0)
- Feng XIE, Kai ZHANG, Dongshen YANG, Shaoyang MA, Siqi CHEN, Tao WANG*. Anti-jamming performance evaluation of infrared aerial target tracking algorithm based on image sequences complexity. Chinese Journal of Aeronautics. 2026. 104147. ISSN 1000-9361. https://doi.org/10.1016/j.cja.2026.104147.(中科院一区TOP SCI IF=6.9)
- Yuyang Xue, Qidong Yu, Tao Wang*, Yanru Huang, Bingsan Yang, Hongrun Wang. Collaborative Control Strategy for Low-Cost Fixed-Wing UAV Swarms based on Deep Q Network[J]. Aerospace Science and Technology. 2025, 111296, (中科院一区TOP JCR Q1 IF= 6.4) https://doi.org/10.1016/j.ast.2025.111296.
- B. Yang, T. Wang*, B. Li, F. Luo and C. Gao, A Vehicle-Target Assignment Framework: Collaborative Missions of Multiple High-Speed Flight Vehicles With Multiple Targets[J], IEEE Transactions on Aerospace and Electronic Systems, Vol. 61, No.6, Dec. 2025, doi: 10.1109/TAES.2025.3595106.(中科院二区SCI TOP IF=7.0)
- Y. Xue, Y. Huang, T. Li, T. Wang* and H. Wang, A Dynamic Evolution Value Assessment Scheme for Maritime Target Groups Based on Attention Mechanism and Hybrid Quantification Methods[J], IEEE Transactions on Aerospace and Electronic Systems, Vol.61, No.5, Oct. 2025. doi: 10.1109/TAES.2025.3570292. (中科院二区SCI TOP IF=7.0)
- X. Lan, Z. Huang, T. Wang, T. Zou and Z. Zhao. Adaptive Fault-Tolerant Control for Quadrotor UAVs via Hybrid MPC-DDPG With Lyapunov-Based Contraction Constraints[J]. IEEE Transactions on Consumer Electronics, vol. 72, no. 1, pp. 1770-1781, Feb. 2026, doi: 10.1109/TCE.2025.3643855. (新锐一区TOP期刊,SCI IF=9.9)
- Feng Xie, Siqi Chen, Dongsheng Yang, Yao Yang, Tao Wang. HOGnet-driven Siamese architecture for quantifying complexity of infrared countermeasure scenarios. Results in Engineering,Volume 29,2026,109515. (中科院工程大类二区,SCI IF=9.4) https://doi.org/10.1016/j.rineng.2026.109515.
- Jiaxin Hu, Tao Wang*, Hongrun Wang, Jingshuai Cao, CogMUS: A Soar-Based Cognitive Framework for Mission Understanding in Multi-UAV Cooperative Operation[J]. Drones2025, 9(12):813. https://doi.org/10.3390/drones9120813 (SCI JCR Q1 IF=4.8 )
- Yang, B.; Wang, T.; Li, B.; Zhan, Q.; Wang, F. Real-Time Trajectory Prediction for Rocket-Powered Vehicle Based on Domain Knowledge and Deep Neural Networks[J]. Aerospace2025, 12, 760. https://doi.org/10.3390/aerospace12090760(SCI JCR Q2 IF=2.4)
- Xie F, Yang D, Yang Y, Wang T, Zhang K. Infrared Small Target Detection Using Directional Derivative Correlation Filtering and a Relative Intensity Contrast Measure. Remote Sensing. 2025; 17(11):1921. https://doi.org/10.3390/rs17111921(中科院二区 SCI JCR Q1 IF=4.8)
- Ding, L.; Tang, Y.; T. Wang*; Xie, T.; Huang, P.; Yang, B. A Cooperative Decision-Making Approach Based on a Soar Cognitive Architecture for Multi-Unmanned Vehicles[J]. Drones 2024, 8, 155. (中科院二区SCI IF=4.4)
- Huang, P.; Tang, Y.; Yang, B.; T. Wang*. Research on Scenario Modeling for V-Tail Fixed-Wing UAV Dynamic Obstacle Avoidance[J]. Drones 2023, 7, 601. (中科院二区SCI IF=4.4)
- Chen F, Tang Y, Li N, Wang T*, Hu Y. A Study of Collaborative Trajectory Planning Method Based on Starling Swarm Bionic Algorithm for Multi-Unmanned Aerial Vehicle[J]. Applied Sciences. 2023; 13(11):6795.(SCI IF=2.838 JCR Q2)
- F. Chen, W. Xue, Y. Tang, T. Wang*. A Comparative Research of Control System Design based on h-infinity and ALQR for the Liquid Rocket Engine of Variable Thrust[J]. International Journal of Aerospace Engineering, vol. 2023, 2023. (SCI IF=1.198 JCR Q3)
- Huang, S., Wang, T.*, Tang, Y., Hu, Y., Xin, G., Zhou, D. Distributed and Scalable Cooperative Formation of Unmanned Ground Vehicles Using Deep Reinforcement Learning[J]. Aerospace 2023, 10, 96. (SCI IF=2.66 JCR Q1)
- Wang T*, Ding L, Yu H. Research and Development of Fault Diagnosis Methods for Liquid Rocket Engines[J]. Aerospace. 2022; 9(9):481. (SCI IF=2.66 JCR Q1)
- Huang P, Wang T*, Ding L, Yu H, Tang Y, Zhou D. Comparative Analysis of Real-Time Fault Detection Methods Based on Certain Artificial Intelligent Algorithms for a Hydrogen–Oxygen Rocket Engine[J]. Aerospace. 2022; 9(10):582. (SCI IF=2.66 JCR Q1)
- Huang P, Yu H, Wang T*. A Study Using Optimized LSSVR for Real-Time Fault Detection of Liquid Rocket Engine[J]. Processes. 2022; 10(8):1643.(SCI IF= 3.352 JCR Q2)
- Y. Fang, L. Zhang*, Sh. Wei, T. Wang*, J. Wu. Online Frequency-Agile Strategy for Radar Detection Based on Constrained Combinatorial Nonstationary Bandit[J]. IEEE Transactions on Aerospace and Electronic Systems, vol. 59, no. 2, pp. 1693-1706, April 2023. (中科院2区Top, JCR Q1 IF=3.491)
- Yu, H.; Wang, T.* A Method for Real-Time Fault Detection of Liquid Rocket Engine Based on Adaptive Genetic Algorithm Optimizing Back Propagation Neural Network[J]. Sensors 2021, 21, 5026.(JCR Q1, SCI IF=3.576)
- 吴安琪,曹敬帅,许新爽,王涛*,谢峰. 机载系统轻量化意图理解模型的部署优化研究[J].航空学报. 2026.8 (EI, 中国科技期刊卓越行动计划-领军期刊,已录用)
- 曹敬帅, 王涛*,杨丙三. 信息非完备下多飞行器协同突防打击方法[J]. 宇航学报. Vol.47,No.9, 2026.9. pp1-11 (EI,中国科技期刊卓越行动计划-领军期刊)
- 薛羽阳,王涛*,廖馨等. 动态对抗场景中的打击链在线重构方法[J]. 系统工程与电子技术,2026,48(6):1980−1990. DOI: 10.12305/j.issn.1001-506X.2026.06.19 (EI)
- 薛羽阳, 王涛*. 非透明场景下基于指标关联特征的地面目标群价值评估方法[J]. 兵工学报, 2026,47(6):250966.DOI: 10.12382/bgxb.2025.0966. (EI 中文领军期刊)
- 薛羽阳;王涛*;李彬;谢峰. 多约束下高超飞行器集群打击角度决策方法[J]. 系统工程与电子技术. 2026.9.2(EI 已录用)
- 王涛*,胡佳鑫,李彬. 面向虚实融合的多无人系统仿真技术研究进展[J]. 无人系统技术, 2025,8(05):66-82. DOI:10.19942/j.issn.2096-5915.2025.05.46.(中文科技核心期刊)
- 王涛*,谢添乐,唐勇,张强,许新爽,高琛.认知模型驱动的无人机集群混合智能协同决策方法研究[J].无人系统技术,2025,v.8(03):109-121.DOI: 10.19942/j.issn.2096-5915.2025.03.28(中文科技核心期刊)
- 王涛*, 郭欢祺, 余华煌. 基于组织行为学的跨域协同机理研究[J]. 无人系统技术, 2021, 4(4):22-29.(中文科技核心期刊)
- 王涛*. 火星探测陆空协同无人系统的研究发展分析[J]. 无人系统技术. 2020, 5(3):1-8. (中文科技核心期刊)
会议论文:
- Xue Y, Zhao L, Wang T*. Deep Neural Network-Based Intelligent Evaluation Method for Space Target Group Value[C]. IFAC-PapersOnLine, 2025, 59(20): 61-66. https://doi.org/10.1016/j.ifacol.2025.11.126 (CAA A类会议, Oral presentation)
- Yang Bingsan, Cao Jingshuai, Hu Jiaxin, T. Wang*. A Deep Learning-based Method for Target Assignment[C]. IFAC-PapersOnLine, 2025, 59(20): 482-487. https://doi.org/10.1016/j.ifacol.2025.11.197 (CAA A类会议)
- J. Hu, T. Wang*, H. Wang, A. Wu and X. Xu. G2P-Rec: Graph-to-Prompt Synergistic Reasoning for Knowledge-Enhanced Recommendation[C]. ICASSP 2026 - 2026 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP), Barcelona, Spain, 2026, pp. 5281-5285, doi: 10.1109/ICASSP55912.2026.11460691.(CCF B类会议, Oral presentation)
- Gao, C., Wang, T.*, Ma, X., Rao, Z., Liu, B.. Collaborative Path Planning Method for Heterogeneous Multi-unmanned Systems Based on Soft Actor-Critic[C]. Proceedings of 5th 2025 International Conference on Autonomous Unmanned Systems (ICAUS). ICAUS 2025. Lecture Notes in Electrical Engineering, vol 1575. Springer, Singapore. https://doi.org/10.1007/978-981-95-7648-7_9(EI,优秀海报论文奖)
- Rao, Z., Wang, T.*, Gao, C., Liu, B.. Task-Oriented Homogeneous Swarm Multi-Geometric Formation Dynamic Transformation Flight Control Algorithm[C]. Proceedings of 5th 2025 International Conference on Autonomous Unmanned Systems (ICAUS). ICAUS 2025.Lecture Notes in Electrical Engineering, vol 1575. Springer, Singapore. https://doi.org/10.1007/978-981-95-7648-7_7(EI)
- J. Li and T. Wang*. A Real-Time Aircraft Fault Diagnosis Method Based on Multimodal Graph Construction[C]. 2025 China Automation Congress (CAC), Harbin, China, 2025, pp. 7863-7868, doi: 10.1109/CAC67268.2025.11487115. (EI)
- X. Liu, J. Ma, S. Tang and T. Wang*. A Multi-Sensor Information-Based Flight Environment Perception and Evaluation System[C]. 2025 China Automation Congress (CAC), Harbin, China, 2025, pp. 7786-7790, doi: 10.1109/CAC67268.2025.11487642. (EI)
- X. Xu, J. Li, J. Cao and T. Wang*. A Cognitive-RAG Framework for Task Planning and Decision Generation[C]. 2025 China Automation Congress (CAC), Harbin, China, 2025, pp. 7904-7909, doi: 10.1109/CAC67268.2025.11487090. (EI)
- M. Lin, B. Li, Y. Xue and T. Wang*. Designing Method of Kill Chains Based on MOEA/D[C]. 2025 IEEE 8th Advanced Information Technology, Electronic and Automation Control Conference (IAEAC), Guiyang, China, 2025, pp. 52-57, doi: 10.1109/IAEAC65194.2025.11166390.(EI)
- J. Cao, T. Wang* and B. Yang. Research on Intelligent Penetration Technology of High Speed Flight Vehicle Based on PPO Algorithm[C]. 2024 International Conference on Intelligent Robotics and Automatic Control (IRAC), Guangzhou, China, 2024, pp. 476-483, doi: 10.1109/IRAC63143.2024.10871523.(EI)
- Liu, B., Rao, Z., Gao, C., Yang, B., T. Wang*. Methods for Formation Control and Path Planning for UAVs and UGVs Swarm[C]. Proceedings of 4th 2024 International Conference on Autonomous Unmanned Systems (4th ICAUS 2024). ICAUS 2024. Lecture Notes in Electrical Engineering, vol 1379. Springer, Singapore. (EI)
- X. Ma, T. Wang*, C. Gao and Z. Rao, Global and Local Fusion Method for Path Planning and Formation Control of Multiple Unmanned Systems[C]. 2024 International Conference on Cyber-Physical Social Intelligence (ICCSI), Doha, Qatar, 2024, pp. 1-6.(EI)
- Xie, T., T. Wang*, Gao, C., Luo, F., Rao, Z.. Modeling Unmanned Cluster Mission Planning Based on Data Fusion and Knowledge Inference[C]. Proceedings of 4th 2024 International Conference on Autonomous Unmanned Systems (4th ICAUS 2024). ICAUS 2024. Lecture Notes in Electrical Engineering, vol 1379. Springer, Singapore. (EI)
- Fangyou Luo, T. Wang*, Chen Gao, Zihao Rao, and Bo Liu. Distributed Formation Coordinated Control of Multiple Unmanned Surface Vehicles Based on Deep Reinforcement Learning[C]. In Intelligent Robotics and Applications: 17th International Conference, ICIRA 2024, Xi’an, China, July 31 – August 2, 2024, Proceedings, Part II. Springer-Verlag, Berlin, Heidelberg, 334–348.(CAA A类会议 EI)
- Fei Wang, Hongrun Wang, Dianle Zhou, and T. Wang*. Homogeneous Multi-robot Patrolling Based on Humanoid Formation Configuration[C]. In Intelligent Robotics and Applications: 17th International Conference, ICIRA 2024, Xi’an, China, July 31 – August 2, 2024, Proceedings, Part II. Springer-Verlag, Berlin, Heidelberg, 403–417. (EI)
- H. Wang, T. Wang*, N. Li, L. Ding and T. Xie. Research on Cognitive Mining Method of Ship Formation Behavior Law Based on Knowledge Graph and Fuzzy Association Logic[C], 2023 China Automation Congress (CAC), Chongqing, China, 2023, pp. 8150-8155.(CAA A类会议 EI)
- Xie, T., Li, N., Wang, H., Ding, L., T. Wang*, Yang, Y.. Research on Construct and Relation Reasoning Method Based on Knowledge Graph[C]. Proceedings of 2023 7th Chinese Conference on Swarm Intelligence and Cooperative Control. CCSICC 2023. Lecture Notes in Electrical Engineering, vol 1207. Springer.(EI)
- Fayin Chen, Yong Tang, Yiwen Hu, Tao Wang*. An optimized flocking starling algorithm for autonomous drones[C]. Proceedings of 2022 International Conference on Autonomous Unmanned Systems (ICAUS 2022). Lecture Notes in Electrical Engineering, vol 1010. Springer, Singapore. pp 3548–3555.(EI)
- Fei Wang, Shichun Huang, Yong Tang, and Tao Wang*. Research on Formation and Path Planning Method of Isomorphic Multi-Unmanned Ground System Based on Humanoid Formation Configuration[C]. Proceedings of 2022 International Conference on Autonomous Unmanned Systems (ICAUS 2022). Lecture Notes in Electrical Engineering, vol 1010. Springer, Singapore. pp 2577–2590. (EI)
- H. Yu, T. Wang* and Y. Tang, A Method Using Quantum Genetic Algorithm optimized BP Neural Network of Real-time Fault Detection for the Liquid Rocket Engine[C]. 2021 Global Reliability and Prognostics and Health Management (PHM-Nanjing), 2021, pp. 1-6, doi: 10.1109/PHM-Nanjing52125.2021.9613130. (CAA A类会议 EI)
发明专利
- 王涛; 刘波; 高琛; 饶子昊; 杨丙三; 汪鸿润; 刘学儒; 李家賀. 一种无人机集群任务执行方法及系统. 专利号:CN202510736934.X.授权日: 2026年3月25日.
- 王涛、饶子昊、刘波、高琛、杨丙三、汪鸿润、刘学儒、李家賀. 基于一致性算法的无人机集群控制设计与仿真方法及系统. 专利号:ZL202510401386.5. 授权日:2025年11月11日
- 王涛、薛羽阳、杨丙三、陈岳东、汪鸿润、詹倩倩、曹敬帅. 一种无人机群飞行控制方法、系统、设备及介质. 专利号:ZL202510176214.2. 授权日:2025年11月04日
- 王涛、王飞、汪鸿润、杨丙三、刘波. 一种资源约束下无人机集群巡逻路径决策方法. 专利号:ZL202510874932.7,授权日: 2025年9月9日.
- 王涛、王飞、汪鸿润、杨丙三、刘波. 一种复杂环境下无人机巡逻路径决策方法. 专利号:ZL 202510876863.3,授权日:2025年12月09日
- 王涛、谢添乐、罗方友、刘学儒. 一种用于飞行器性能测试的测试用例生成方法及生成平台. 专利号:ZL202510358756.1, 2025年10月3日.
- 王涛、高琛、饶子昊、刘波、杨丙三、汪鸿润、刘学儒、李家賀. 一种无人机集群协同控制方法、系统及无人机系统. 专利号:ZL202510554670.6, 授权日:2025年11月4日.
- 王涛、杨丙三、詹倩倩. 一种弹道快速解算方法、系统、计算机设备和存储介质. 专利号:ZL 202411834962.7,授权日:2025年10月14日
- 王涛、詹倩倩、杨丙三、汪鸿润、刘波、高琛、胡佳鑫. 一种基于时空解耦图卷积网络的手势识别方法和装置. 专利号:ZL 202510531178.7. 授权日:2025年10月28日
- 王涛,薛羽阳,杨丙三,汪鸿润,詹倩倩. 一种面向动态场景的智能权重预测方法. 专利号:ZL202511059319.6. 授权日:2026 年 02 月 17 日
- 王涛;胡佳鑫;陈岳东;杨丙三;汪鸿润;高琛;曹敬帅. 基于图神经网络和认知架构的智能推荐决策方法及系统. 专利号:ZL 202511239661.4. 授权日:2026年03月06日
- 王涛;邵金鑫;苗建明;张淏酥;徐灵基;龚喜;刘涛. 一种基于全局金字塔线性调制的水下图像增强方法及系统. 专利号:ZL202411083523.7. 授权日:2026年01月30日
- 王涛,詹倩倩,谢峰,饶子昊,刘波. 基于时空解耦和动态图过滤的轻量级手势预测方法及装置. 专利号:ZL202610467520.6. 授权日:2026年6月11日.
- 王涛,汪鸿润,薛羽阳,刘学儒,胡佳鑫,刘波,许新爽,詹倩倩. 一种基于节点感知注意力的异构图补全方法及相关设备. 专利号:ZL202610050493.2. 授权日:2026-08-18.
- 张淏酥、王涛、苗建明、龚喜、任磊、郑若晗、孙兴宇、仝懿聪. 一种无人机快速对准方法、系统、计算机设备及存储介质发明专利证书. 专利号:ZL 202211381425.2. 授权日:2024年07月05日
- 张淏酥、王涛、苗建明、任磊、龚喜、蔡华阳. 一种水下动基座的基座定位方法、装置、存储介质及设备. 专利号:ZL 202310351836.5. 授权日:2024年02月23日
- 张淏酥、王涛、苗建明、龚喜、任磊、蔡华阳、郑若晗. 基于磁罗盘与测速仪的水下动基座高精度对准方法及系统. 专利号:ZL 202211382650.8. 授权日:2025年09月26日
- 张淏酥、苗建明、王涛、任磊、龚喜、蔡华阳、彭超、郭志群、 陈顺华、徐灵基、郑若晗. 一种深海水下无人航行器惯导方法、系统、设备及介质. 专利号:ZL 202211421803.5. 授权日:2025年08月01日
- 张淏酥;马成;郑若晗;王涛;苗建明;龚喜;彭超;任磊;徐灵基. 一种基于交互卡尔曼模型的时变洋流估算方法及系统. 专利号:ZL 2023 1 0341372.X. 授权日:2025年06月06日
学术专著
1、王涛、唐勇、薛薇,多域无人系统智能协同认知控制技术,哈尔滨工业大学出版社, 17万字,2025.5
2、T. Wang. Invited Chapter: Computational Modeling for Predicting the Optical Distortions through the Hypersonic Flow Fields[M]. in Numerical Simulation. London, United Kingdom: IntechOpen, 2022 [Online]. DOI: 10.5772/intechopen.106591
学术/社会兼职
西安交通大学人工智能校友会 副秘书长
中国计算机自动测量与控制技术协会 理事
《无人系统技术》理事、第三届编委
《计算机测量与控制》 编委
《科技纵览》(IEEE Spectrum中文版) 编委
《Biomimetic Intelligence and Robotics》 青年编委
Reviewer Board for Journal of Human Cognition
中国航天科工二院未来实验室专家委员会专家
中航集团(中航无人机)人工智能实验室 智能感知领域专家
复杂系统控制与智能协同技术全国重点实验室 客座教授
中国自动化学会高级会员、自动化学会混合智能专委会委员/系统仿真专委会/导航制导与控制专委会/具身智能专委会委员
中国指挥与控制学会高级会员、集群智能与协同控制专委会/智能博弈与兵棋推演专委会/大模型与决策智能专委会/无人系统专委会/低空经济产业工作委员会委员
中国宇航学会飞行器任务规划专委会委员
中国图象图形学学会视觉传感专委会委员
广东省研究型医院学会放射肿瘤专委会常务委员